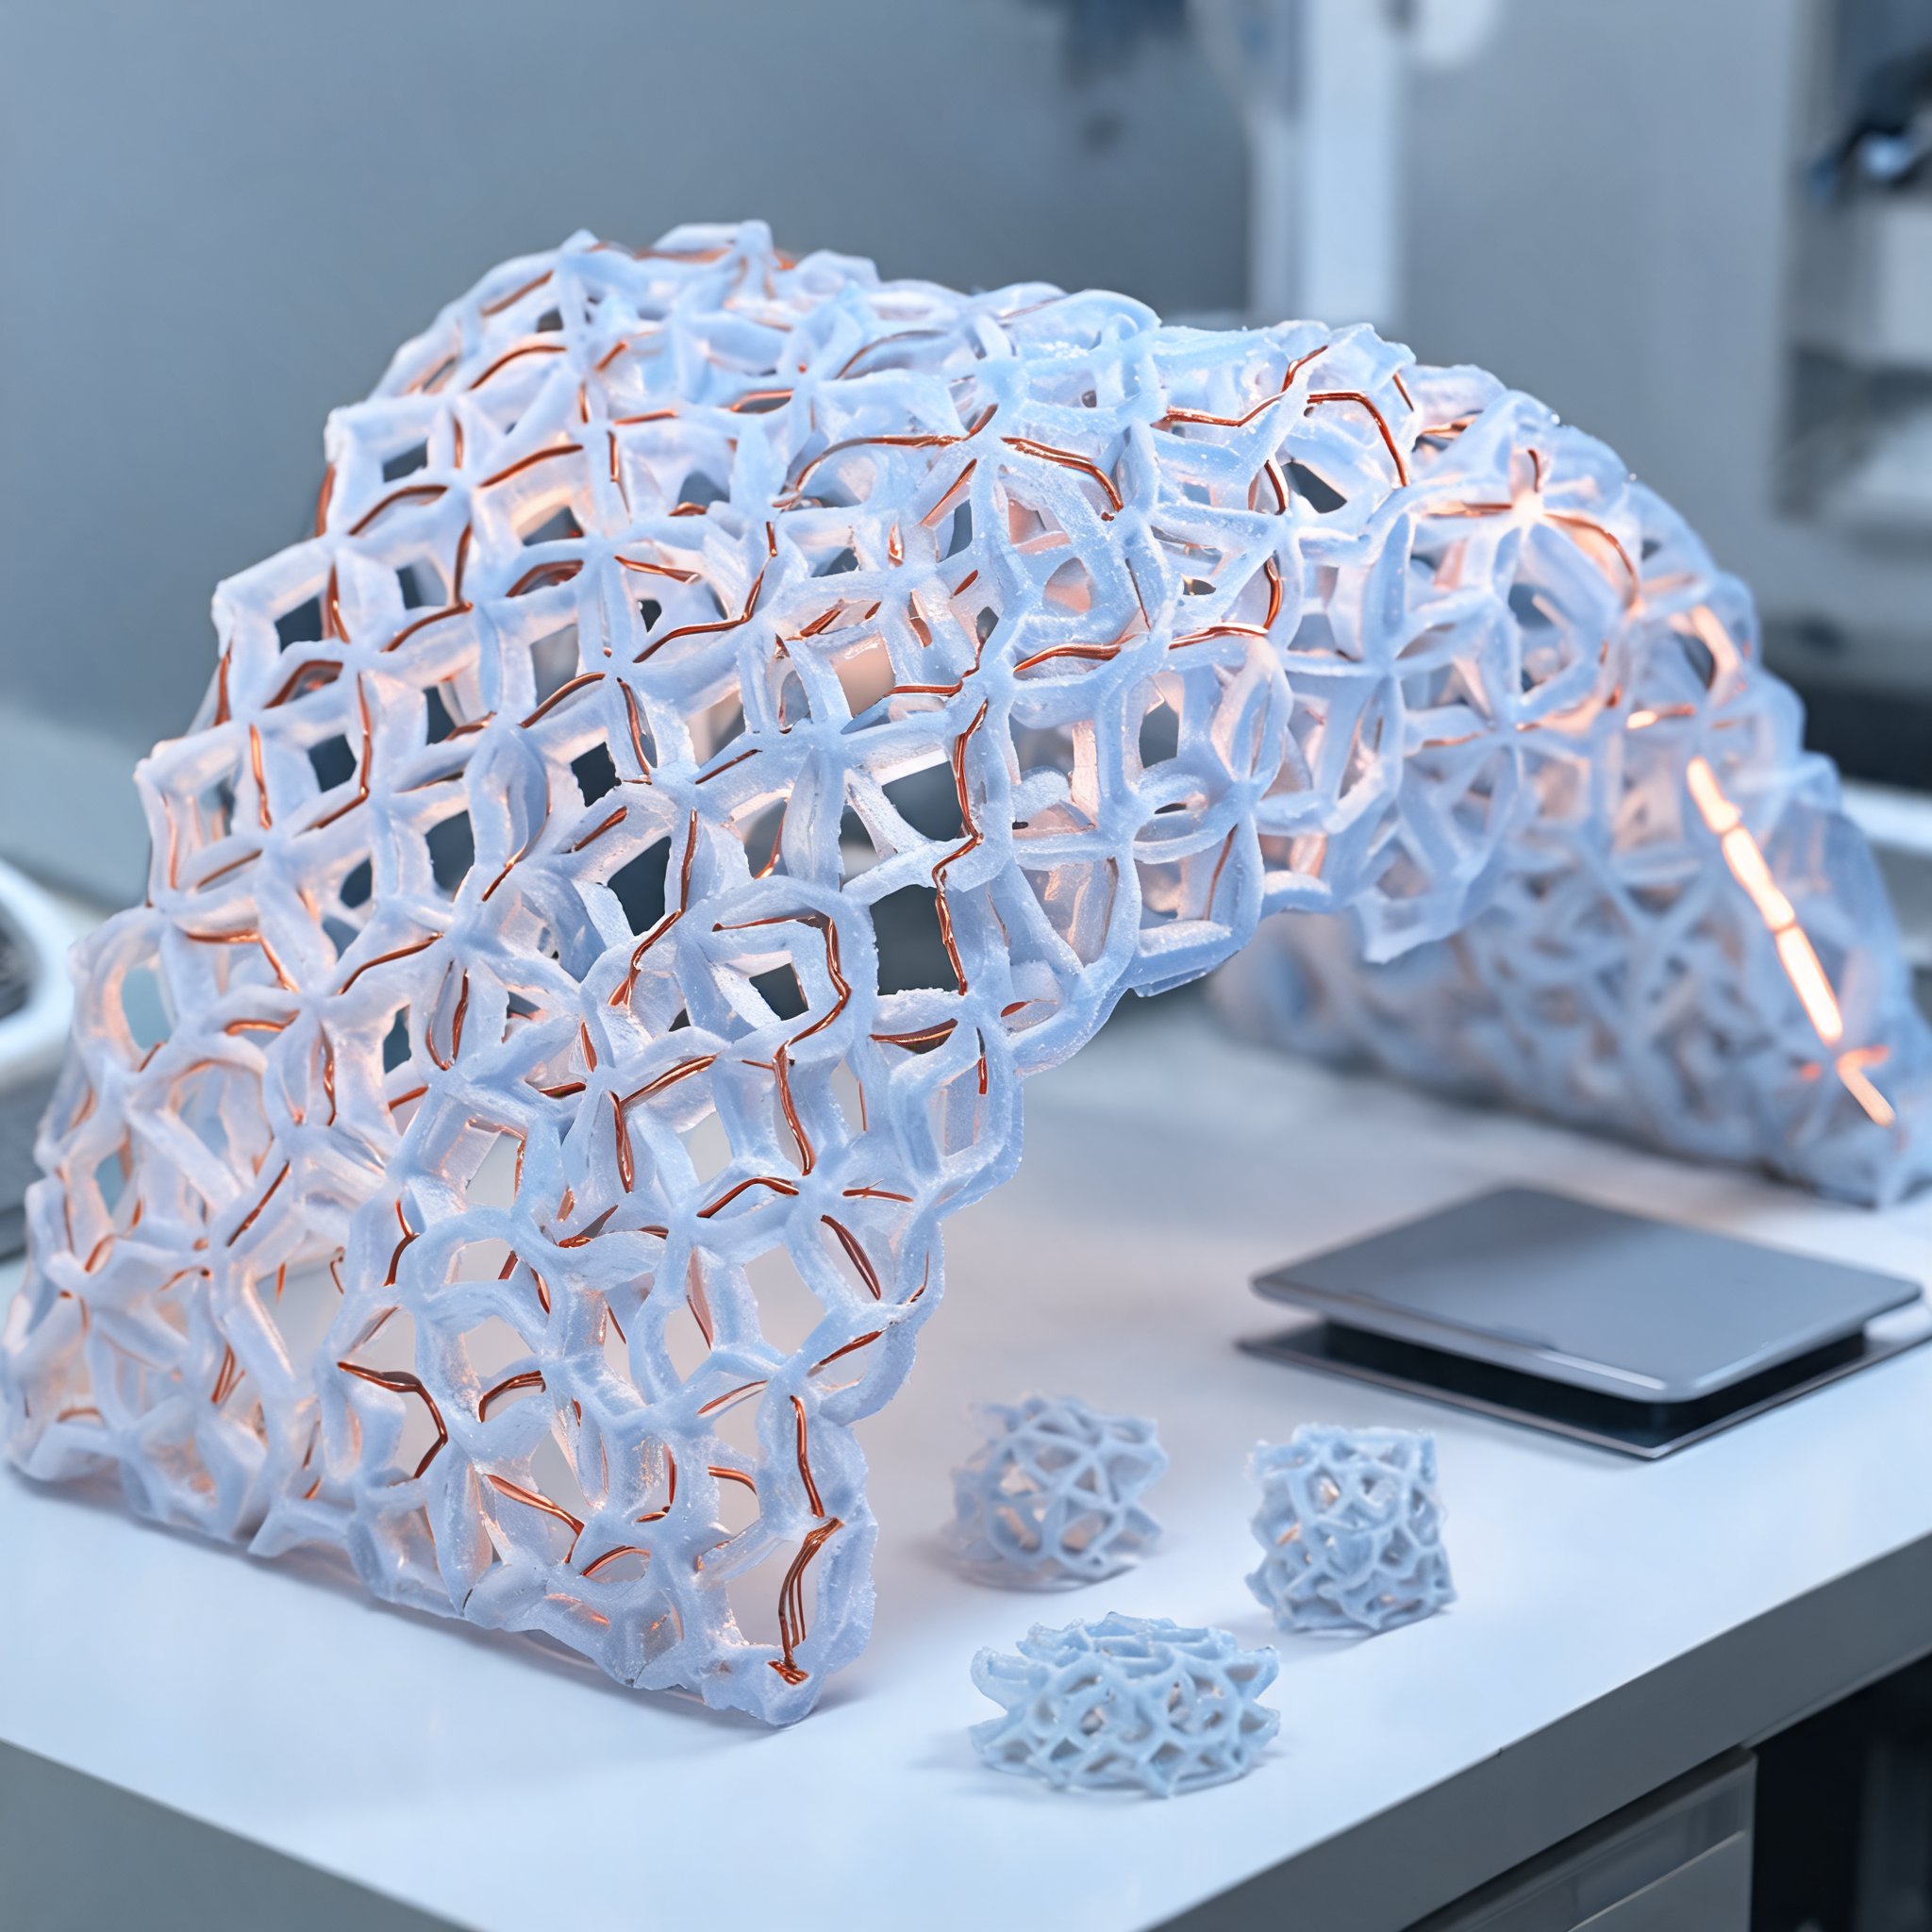
Meisam Abdi, a researcher at De Montfort University Leicester in the UK, has been awarded a 2026/27 Royal Academy of Engineering/Leverhulme Trust Research Fellowship to investigate whether additive manufacturing can produce artificial muscles for soft robots.
Abdi was one of eight engineers in the UK to receive the award, which funds up to a year of research into materials and structures intended to let robots move, sense and respond more like living organisms.
Moving away from rigid structures
Abdi framed the work around safety in human-facing environments such as hospitals. “If we want people to interact safely with robots in places such as hospitals, we need to move away from completely rigid structures and think about how we can give robots some of the attributes we see in living systems,” he said.
Rather than reproducing the physical structure of a human muscle, Abdi plans to use 3D printing to design architected structures whose geometry gives them specific properties. Combinations of piezoelectric, conductive and structural materials and architectures will be modelled with computer-aided engineering, 3D printed, and tested in the laboratory for their response to electrical stimulation.
The longer-term aim is artificial muscles that can produce movement, sense their environment and harvest small amounts of electrical energy from mechanical movement or vibration.
Piezoelectric materials as the starting point
The project focuses on piezoelectric materials, which can convert mechanical deformation into electrical energy and deform under an applied electric field. According to DMU, existing high-performance piezoelectric materials are often stiff and brittle, and some of the most widely used contain lead — factors that complicate the development of soft, flexible and more sustainable artificial muscles.
Abdi's approach combines material composition with specially designed 3D printed cellular structures to reach the required properties while remaining soft and flexible.
That combination matters for the project's premise: if geometry can be tuned alongside chemistry, printed cellular architectures might deliver useful actuation and sensing while staying compliant, rather than depending only on stiff and brittle high-performance piezoelectrics, some of which contain lead.
He described the goal as designing properties rather than copying nature. “Biological systems are remarkable because they can combine movement, sensing and responses to external stimuli. The question for us is whether we can design and manufacture an artificial structure that can reproduce some of those functions,” he said. “We aren't trying to copy something that already exists in nature. By changing the materials and the geometry of these structures, we want to see whether we can create properties that don't currently exist naturally.”
Planned work, not a finished device
The award funds up to a year of research, and the work described is planned rather than completed: material combinations and architectures are to be modelled, printed and tested, and a prototype remains an ambition for the fellowship period. Abdi described the project as ambitious, noting that soft robotics already attracts significant research effort but that replicating the multiple functions of living muscle remains a major challenge.
His stated ambition for the fellowship is to develop a prototype that demonstrates what is possible and can provide the foundation for further research.